
How to efficiently machine shaped parts on CNC mill-turn machines?
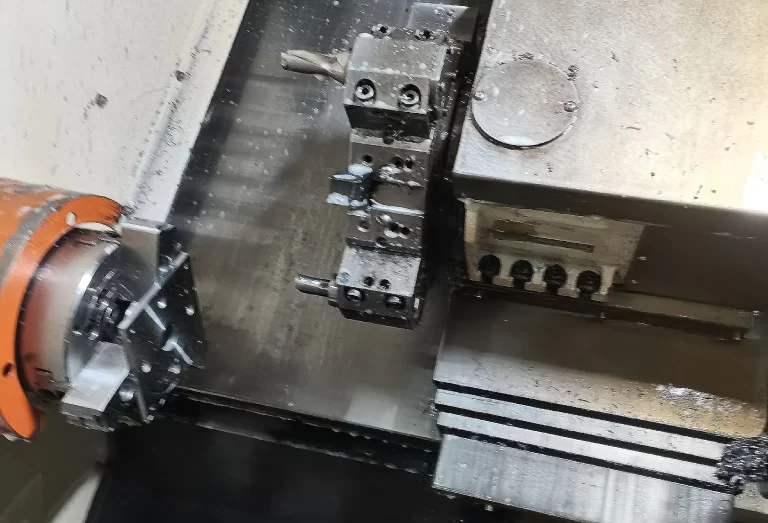

On the same machine tool, the positioning accuracy obtained varies depending on the standards used; Therefore, when selecting accuracy specifications for a CNC machine tool, it is important to consider the standards it employs.
The positioning standards for CNC machine tools typically refer to the reverse deviation and positioning accuracy of each CNC axis.
Measuring and compensating for these two factors are essential for improving machining accuracy.
In CNC machine tools, each coordinate axis has a feed drive train. The drive components on this train include servo motors, servo hydraulic motors, and stepper motors.
These components have errors such as reverse dead zones. In addition, the mechanical motion transmission pairs also have reverse clearance.
When each coordinate axis switches from forward motion to reverse motion, all these errors will lead to reverse deviation.
This is commonly referred to as reverse clearance or loss of motion. Semi-closed-loop servo systems can be installed on CNC machine tools.
Reverse deviation exists in such machine tools. This reverse deviation impairs the positioning accuracy and repeatability of the machine.
As a result, the machining accuracy of the workpiece is affected. For example, during G01 cutting movements, reverse deviation affects the accuracy of interpolation;
If the deviation is too large, it can result in “circles that are not perfectly round and squares that are not perfectly square.”
During G00 rapid positioning movements, reverse deviation affects the machine tool’s positioning accuracy, reducing the positional accuracy between holes during hole-making operations such as drilling and boring.
Furthermore, as the equipment accumulates operating hours, reverse deviation increases due to the gradual expansion of clearance between moving pairs caused by wear.
Therefore, it is necessary to periodically measure and compensate for the reverse deviation of each coordinate axis on the machine tool.
Method for measuring reverse deviation:
Within the travel range of the coordinate axis being measured, first move a certain distance in the forward or reverse direction and use the resulting stop position as the reference point.
Then, issue a specific movement command in the same direction to move a certain distance, followed by moving the same distance in the opposite direction.
Measure the difference between the stop position and the reference position.
Perform multiple measurements (typically seven) at three positions—near the midpoint and at both ends of the travel range—and calculate the average value at each position.
The maximum value among these averages is taken as the reverse deviation measurement.
When measuring, it is essential to move the axis a certain distance first; otherwise, an accurate reverse deviation value cannot be obtained.
When measuring the reverse deviation of a linear motion axis, a dial indicator or vernier caliper is typically used as the measuring tool;
If conditions permit, a dual-frequency laser interferometer may be used for measurement. A dial indicator or vernier caliper may be used for measurement. Operators need to pay attention during operation.
They must prevent the indicator base and stem from extending too high or too far. A long cantilever will form in the measurement setup if they extend excessively.
Force applied during measurement may shift the base under this condition. This will lead to inaccurate readings. Subsequently, the obtained compensation value becomes unreliable.
If a programmed measurement method is used, the measurement process becomes more convenient and precise.
This serves as an example. We will measure the reverse deviation of the X-axis on a vertical coordinate measuring machine.
First, press the dial gauge against the cylindrical surface of the spindle. Then run the following program to complete the measurement.
It should be noted that the measured results will vary depending on the table’s operating speed.
Generally, the measured values at low speeds are higher than those at high speeds, especially when the machine tool’s axis load and motion resistance are significant.
During low-speed operation, the table’s speed is lower, making it less likely to experience overshoot (relative to “backlash”); therefore, the measured values are higher.
At high speeds, however, because the table’s speed is higher, overshoot is more likely to occur, resulting in lower measured values.
The method for measuring reverse deviation on rotary axes is the same as for linear axes;
The only difference is the instrument used for the measurement.
Many domestically produced CNC machine tools have positioning accuracies greater than 0.02 mm but lack a compensation function.
For such machines, in certain situations, unidirectional positioning can be achieved through programming to eliminate reverse backlash.
Without modifying the mechanical components, the tool can first perform low-speed unidirectional positioning to reach the start point of the interpolation, and then begin interpolation machining.
Reverse direction may appear during interpolation feed. If this situation occurs, the reverse clearance value should be applied in advance.
This action is carried out before formal interpolation starts. It can raise the accuracy of interpolation machining.
In essence, it guarantees that the tolerance requirements of the part can be satisfied.
For other types of CNC machine tools, the CNC unit’s memory typically contains several addresses specifically designated for storing the reverse play values of each axis.
A machine tool axis may receive an instruction to reverse its motion direction.
At this moment, the CNC unit automatically reads the reverse play value corresponding to this axis. It compensates and corrects the coordinate displacement command value.
This allows the machine tool to achieve accurate positioning at the commanded position.
As a result, the adverse impacts of reverse play on machine accuracy can be eliminated or reduced to a minimum.
Generally, CNC systems provide only a single backlash compensation value.
To balance motion accuracy at both high and low speeds, aside from improving the mechanical design, the only option is to use the backlash value measured during rapid motion as the compensation value.
Consequently, it is difficult to achieve a balance between rapid positioning accuracy and interpolation accuracy during cutting.
For CNC systems such as the FANUC 0i and FANUC 18i, there are two types of backlash compensation available:
one for rapid motion (G00) and one for low-speed cutting feed motion (G01).
Depending on the feed mode, the CNC system automatically selects the appropriate compensation value to achieve higher machining accuracy.
Enter the backlash value A measured during G01 cutting feed motion.
Enter parameter NO11851 (the test speed for G01 can be determined based on commonly used cutting feed rates and machine tool characteristics), and enter the backlash value B measured during G00.
Input parameter NO11852. Note that if you want the CNC system to perform separately specified backlash compensation, set the fourth digit (RBK) of parameter 1800 to 1;
If RBK is set to 0, separately specified backlash compensation will not be performed. G02, G03, and JOG use the same compensation values as G01.
The positioning accuracy of a CNC machine tool refers to the positional accuracy that the machine tool’s moving components can achieve when controlled by the CNC system.
It is a key accuracy parameter that distinguishes CNC machine tools from conventional machine tools.
Together with the machine tool’s geometric accuracy, it significantly influences machining accuracy, particularly exerting a decisive influence on hole spacing errors in hole-to-hole machining.
The machining accuracy of a CNC machine tool can be determined by the positioning accuracy it achieves;
Therefore, testing and compensating for the positioning accuracy of CNC machine tools is essential for ensuring machining quality.
Currently, dual-frequency laser interferometers are widely used for machine tool inspection and data analysis.
By utilizing the principles of laser interferometry and taking the real-time laser wavelength as the measurement reference, this method improves testing accuracy and broadens the scope of application.
The inspection procedure is as follows:
If the measured positioning error of a CNC machine tool exceeds the permissible error range, error compensation must be performed on the machine tool.
A common method is to calculate a pitch error compensation table and manually enter it into the machine tool’s CNC system to eliminate positioning errors.
However, since there may be hundreds or even thousands of compensation points across the three or four axes of a CNC machine tool, manual compensation is time-consuming and prone to errors.
A computer can be connected to the machine tool’s CNC controller.
The connection is established through an RS-232 interface. Automatic calibration software developed in VB is adopted.
This software controls the laser interferometer. It makes the interferometer work synchronously with the CNC machine tool.
With this setup, we can automatically detect the machine tool’s positioning accuracy. Automatic pitch error compensation can also be realized.
The compensation method is as follows:
We first assess the accuracy status of each axis on the CNC machine tool.
The pitch error automatic compensation function and backlash compensation function are then used.
Operators can reasonably select and distribute compensation points for every axis. This allows the CNC machine tool to reach its optimal accuracy level.
Meanwhile, the efficiency of measuring the machine tool’s positioning accuracy is greatly enhanced.
Positioning accuracy is a critical performance indicator for CNC machine tools.
Although users can select machines with high precision and minimal error during the purchasing process, as the equipment remains in service for longer periods, wear and tear increases, leading to progressively greater positioning errors.
This has a detrimental impact on the machining and production of parts.
We can adopt the above methods. These methods are used to accurately measure and compensate reverse deviation and positioning accuracy.
The measurement and compensation cover all coordinate axes of the machine tool.
Through this approach, the adverse effects of reverse deviation on machine accuracy can be effectively reduced or eliminated.
This improves the machine’s positioning accuracy, maintains it in an optimal state, and thereby ensures the quality of machined parts.
With the rapid development of the modern manufacturing industry, the…
Easy to deform thin-walled parts processing, has been the processing…
Now we attach importance to the design of intelligent agricultural…